2026 Top ETEL Motion Control Types for Global Buyers
Global buyers entering 2026 need more than a catalogue of motors, stages, and controllers. They need a practical map of ETEL motion control types, matched to real production demands. Semiconductor tools may prioritize nanometer-level positioning, while medical equipment often requires quiet operation, repeatability, and compact integration. Packaging lines demand speed, durability, and predictable maintenance intervals.
ETEL founder Jean-Pierre Cottier captured this engineering principle: “Precision matters only when it remains stable in real operating conditions.” That idea remains useful for evaluating direct-drive torque motors, linear motors, air-bearing stages, rotary stages, and complete motion platforms. A high peak speed looks impressive. It means little if thermal drift appears beside a laser, wafer, or inspection camera.
The guide will compare these technologies through measurable criteria. Buyers should examine continuous force, acceleration, feedback resolution, stiffness, heat dissipation, cable routing, controller compatibility, and environmental protection. Supplier documentation matters. So do application tests under representative loads.
Details decide outcomes.
A stage that performs well in a clean laboratory may struggle in a warm factory cell. Some specifications also appear difficult to compare across manufacturers. That is a genuine limitation, not a minor inconvenience. This overview therefore focuses on selection logic, integration risks, and evidence-based comparisons. It also recognizes that the best ETEL motion solution is not always the most powerful option. The right choice balances precision, lifecycle cost, delivery support, and engineering confidence for each global buyer’s application.
ETEL Motion Control Defined: 5 Key Specifications Global Buyers Must Compare
2026 Top Motion Control Types for Global Buyers
ETEL Motion Control Defined: 5 Key Specifications Global Buyers Must Compare
Global buyers should compare motion systems by measurable performance, not attractive catalog language. The International Federation of Robotics reported 541,302 industrial robots were installed worldwide in 2023. This demand increases pressure on positioning systems used in assembly, inspection, semiconductor, and medical equipment. Five specifications deserve close attention: accuracy, repeatability, speed, load capacity, and feedback resolution.
Accuracy shows how closely an axis reaches its commanded position. Repeatability measures whether it returns to the same point. They are different. A system may repeat well but remain consistently offset. Speed and acceleration reveal production potential, yet higher speed can increase vibration and settling time. Load capacity should include moving mass, tooling, and process forces. Underestimating this figure can shorten service life.
Feedback resolution affects control precision, while bandwidth influences response during rapid changes. The International Federation of Robotics also recorded a global operational stock exceeding four million industrial robots in 2023, showing how performance consistency matters at scale. Buyers should request test conditions, thermal data, and error maps. Generic figures are not enough. A practical concern is often missed: laboratory accuracy may decline after hours of continuous operation. Independent acceptance testing is wiser, although it adds time and cost.
2026 Top Motion Control Types for Global Buyers
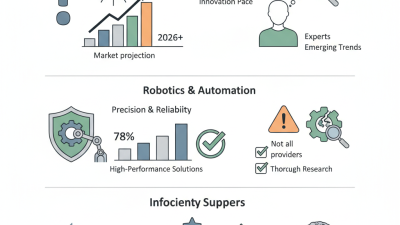
This comparison shows representative positioning repeatability ranges for five widely used motion-control types. Lower values indicate finer positioning performance. Actual results depend on encoder resolution, mechanical design, drive tuning, load, and operating conditions.
Linear Motors: Up to 10 m/s Speed for High-Throughput Precision Stages
2026 Top ETEL Motion Control Types for Global Buyers
Linear motors are becoming a strong choice for high-throughput precision stages. In suitable designs, they can reach speeds of up to 10 m/s while maintaining smooth, contactless motion. This performance supports inspection, electronics handling, laser processing, and other applications requiring rapid positioning. Unlike screw-driven systems, linear motors avoid mechanical contact between the drive components. That can reduce backlash, wear, and maintenance demands. However, high speed alone does not guarantee precision. Encoder resolution, servo tuning, stage stiffness, cable management, and vibration control all affect real results.
Tips: Ask for measured acceleration, repeatability, settling time, and thermal data. Check performance under your actual payload. A clean laboratory test may not represent production conditions.
A reliable evaluation should examine the complete motion system, not only the motor. Cooling may be necessary during continuous high-speed cycles. Air bearings or precision rollers can improve movement quality, but they also change integration costs and service requirements. In my experience, the best design is rarely the fastest one on paper. A 10 m/s headline can distract buyers from settling behavior and long-term stability. That is an easy mistake. Global buyers should request application-specific test records, environmental limits, safety documentation, and clear support terms. Some specifications remain difficult to compare across suppliers, so independent verification is still worthwhile.
Torque Motors: 1,000–6,000 rpm Direct Drive Without Gear Backlash
Torque motors are becoming a practical choice for motion systems requiring smooth rotation from 1,000 to 6,000 rpm. Their direct-drive structure removes gearboxes, reducing backlash, noise, and mechanical wear. This matters in rotary tables, inspection spindles, semiconductor equipment, and precision cutting systems.
The motor connects directly to the driven load. Fewer parts mean fewer alignment problems. An encoder can report shaft position immediately, helping the control system correct small speed errors. At 3,000 rpm, stable feedback can support consistent indexing and cleaner surface results. However, speed alone is not enough. Engineers must check continuous torque, peak torque, rotor inertia, cooling capacity, and bearing loads. A compact motor can still overheat during repeated acceleration.
Thermal behavior deserves close attention. In a factory trial, a motor may perform well for ten minutes, then lose accuracy after sustained cycling. That detail is easy to miss. Cooling channels, mounting stiffness, cable routing, and encoder resolution all affect real performance. Direct drive also exposes weaknesses in the machine frame. Vibration may come from the load, not the motor.
Selection should include measured duty cycles and actual load data. A larger motor is not automatically safer or more efficient. Rushed sizing often creates unnecessary mass and slower response. Engineers should test acceleration, settling time, emergency stopping, and temperature rise under realistic conditions. Some applications still need reduction gearing. Direct drive is powerful, but it is not a universal answer.
Piezo Stages: Sub-Nanometer Resolution for Semiconductor Nanopositioning
2026 Top ETEL Motion Control Types for Global Buyers
Piezo stages are becoming essential for semiconductor nanopositioning, where a wafer inspection point may move by only a few nanometers. Their small motion range supports extremely fine placement, often below one nanometer in controlled conditions. That level of resolution can reveal alignment errors invisible to conventional motorized stages.
A piezo stage uses crystal deformation to create motion without mechanical gears. The design reduces backlash and supports fast, repeatable adjustments. However, open-loop operation can suffer from hysteresis and creep. Closed-loop feedback, usually from capacitive sensors, improves positional reliability.
Thermal drift still matters. A warm enclosure, cable movement, or nearby equipment can affect measurements.
Global buyers should examine accuracy, repeatability, travel range, load capacity, bandwidth, and controller compatibility. Ask for test conditions, not only headline specifications. Sub-nanometer resolution does not automatically mean sub-nanometer accuracy. That assumption is often wrong.
Installation also requires a rigid platform, clean wiring, and vibration control. In practical evaluations, engineers should compare settling time under the real payload.
No stage is perfect. A slightly slower model may deliver better stability in a production environment, while an aggressive control setting can create unwanted oscillation. Careful validation remains necessary before integrating a piezo stage into advanced semiconductor tools.
Buyer Selection: Accuracy, Repeatability, Duty Cycle, and 10-Year ROI
Global buyers evaluating ETEL motion control types in 2026 should begin with the machine’s real workload. A direct-drive rotary motor may deliver smooth positioning, while a linear motor suits rapid, friction-free travel. For high-load indexing, a geared stage can offer useful torque, but backlash requires careful checking. Accuracy describes closeness to the target. Repeatability describes returning to the same point. They are not interchangeable. In factory trials, inspect encoder resolution, thermal drift, settling time, and performance after warm-up. A cold morning test can look excellent. Production heat may change the result.
Duty cycle deserves equal attention. A stage rated for short moves may struggle during continuous acceleration. Frequent reversals and heavy payloads add stress. Ask for tested load curves, not only headline speed. Check lubrication intervals, cable movement, cooling needs, and service access. These details influence downtime more than a perfect brochure specification.
For 10-year ROI, compare purchase price with energy use, calibration, spare parts, lost production, and technician hours. Use measured cycle data from your line, not optimistic estimates. A cheaper unit can become expensive after repeated tuning. My own preference is to model three cases: expected, harsh, and inconvenient. The inconvenient case matters. It includes supply delays, operator learning, and one unplanned replacement. Still, ROI models are imperfect. Leave assumptions visible, then review them after six months of operation.